Table of contents
Automated Assembly Work Cell
Description
The Automated Assembly Work Cell, located at University of Belgrade, Faculty of Mechanical Engineering, consists of two electropneumatic manipulators (Figure 1). The first manipulator (manipulator M1 – on the left side) has three degrees of freedom (DoF) – two translatory and one rotational, whereas the second manipulator (manipulator M2 – on the right side) has two translatory DoF. All DoF are realized by double-acting pneumatic cylinders (linear and rotary) operated using 5/2-way monostable directional control valves with electropneumatic actuation. The end positions of the cylinders are detected by inductive proximity sensors – one for extracted and one for retracted position of each cylinder.
Manipulators are equipped with pneumatic two-finger parallel grippers also controlled using 5/2-way monostable directional control valves. The gripper installed on 3-DoF manipulator has two proximity sensors – one for open and one for closed position, whereas the grasping of objects using 2-DoF manipulator is controlled using actuation signals and timers. The cell contains a total of 12 sensors and 7 actuators.
a) 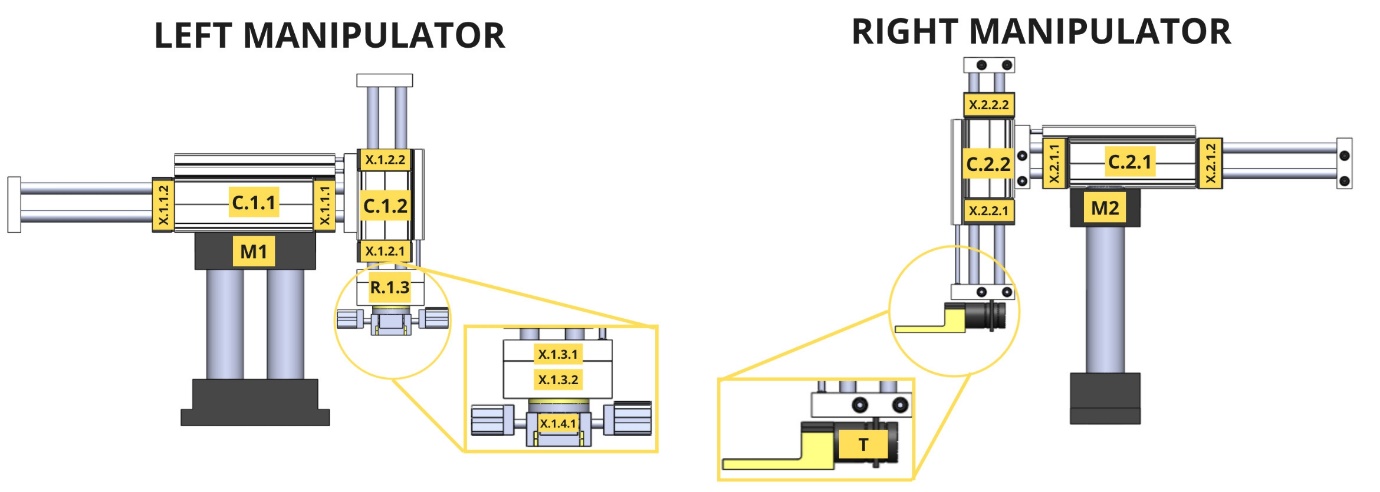
b) 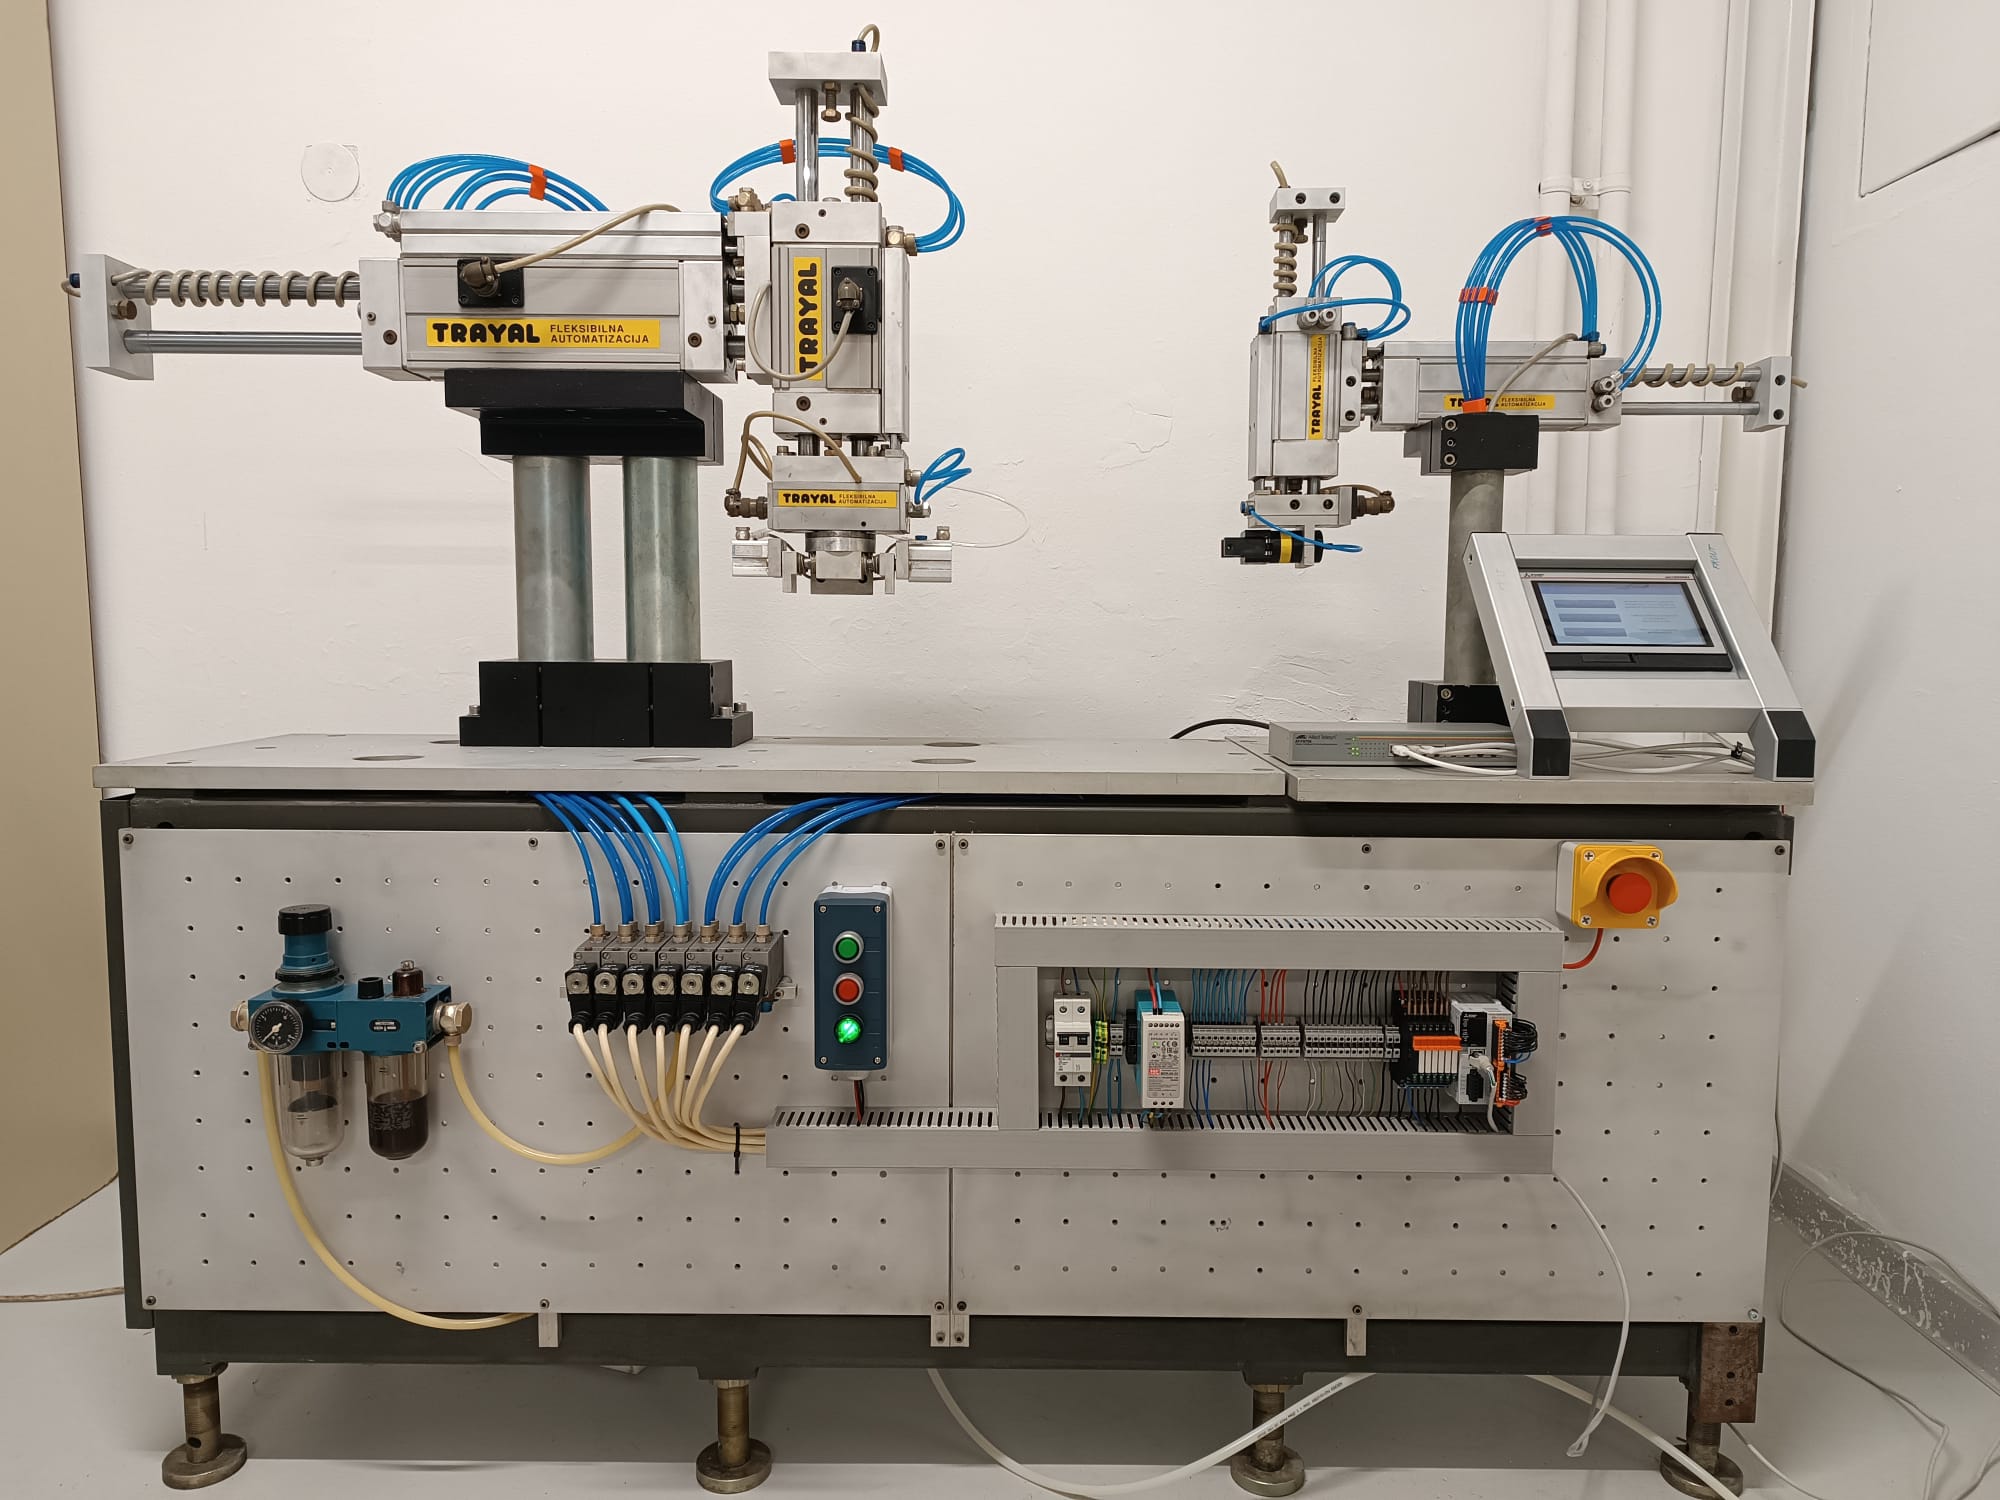
Figure 1: Automated assembly work cell in the workflow: a) 2D representation, b) photo